Three controllers, one contact.
Who learns in time?
A side-by-side race between adaptive interaction controllers on the same two-link arm.
Code to be released after peer reviewROBOTICS · CONTROL · HUMAN–ROBOT INTERACTION
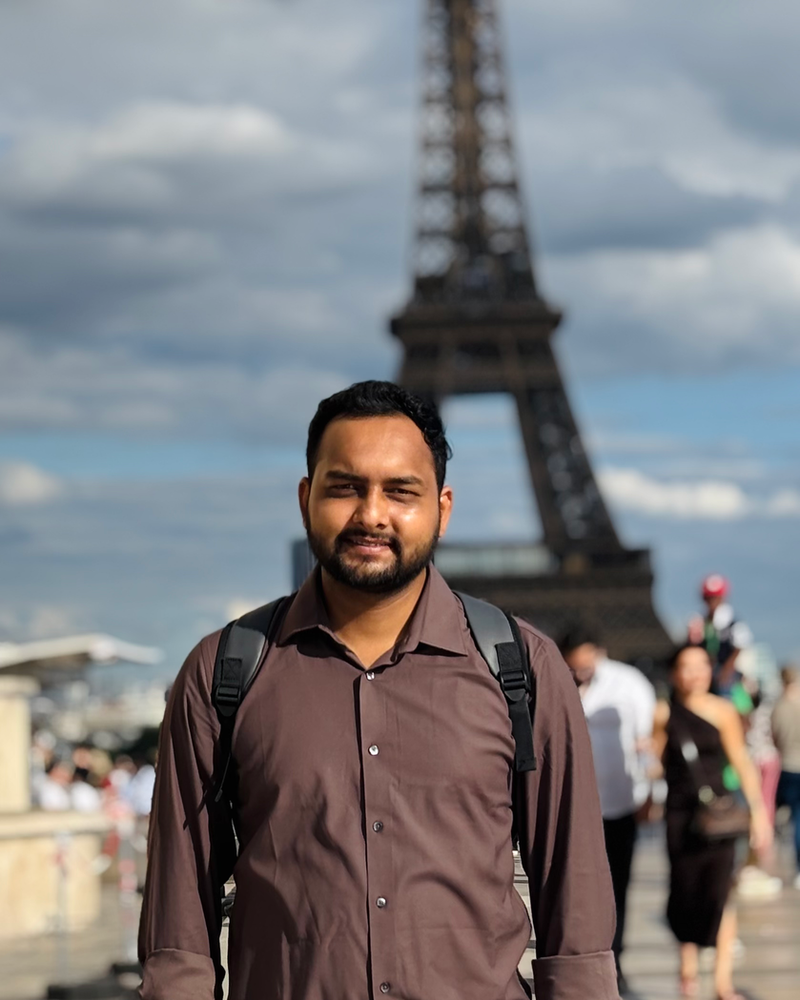
I’m Chayan, a researcher building control strategies for robots that share our world.
Research Associate at FOCAS Lab, Indian Institute of Science, Bangalore.
Ph.D., IIT Delhi · Prime Minister’s Research Fellow
COLLABORATION
I’m always happy to talk about research collaborations in safe robotics, adaptive control, and physical human–robot interaction.
I’m interested in connecting rigorous control methods with experimental robotics, and in working with people who care about both. I’m also open to postdoctoral opportunities.
01 / RESEARCH
Contact changes everything. I build controllers that learn, estimate and plan while a robot is touching the world, and then I take them to hardware.
Whatever the robot starts out believing, its estimates of what it doesn’t know settle within a fixed horizon.
Fixed-time adaptation · parameter convergenceAdaptive control with fixed-time convergence
Funnel-based impedance
Output-feedback control
Dynamic observers
MPC for safe interaction
OPEN RESEARCH
The models and implementations behind my research directions. Code is released once the related papers clear review.
A side-by-side race between adaptive interaction controllers on the same two-link arm.
Code to be released after peer reviewOne direction yields to contact while the rest keeps planning ahead.
Code to be released after peer review02 / PUBLICATIONS
Work on contraction theory, adaptive control, observers, and safe interaction. Also on Google Scholar ↗.
No publications match. Try another title, topic, or year.
Under double-blind review: three further manuscripts, at IEEE T-ASE, IEEE RA-L and ICRA.
10th International Conference on Control, Decision and Information Technologies. Paper on safe human–robot interaction with switched model reference admittance control.
8th IFAC Conference on Advances in Control and Optimization of Dynamical Systems. Two papers: adaptive impedance control through contraction theory, and finite-time adaptive backstepping for quadrotors.
Hands-on programming and operation of industrial KUKA manipulators.
03 / IN THE LAB
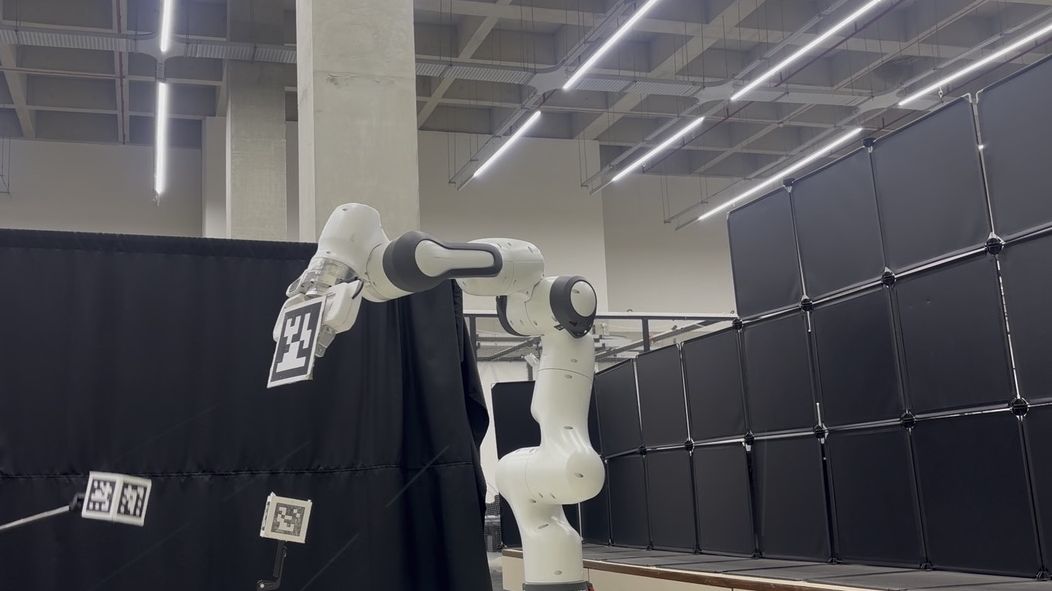
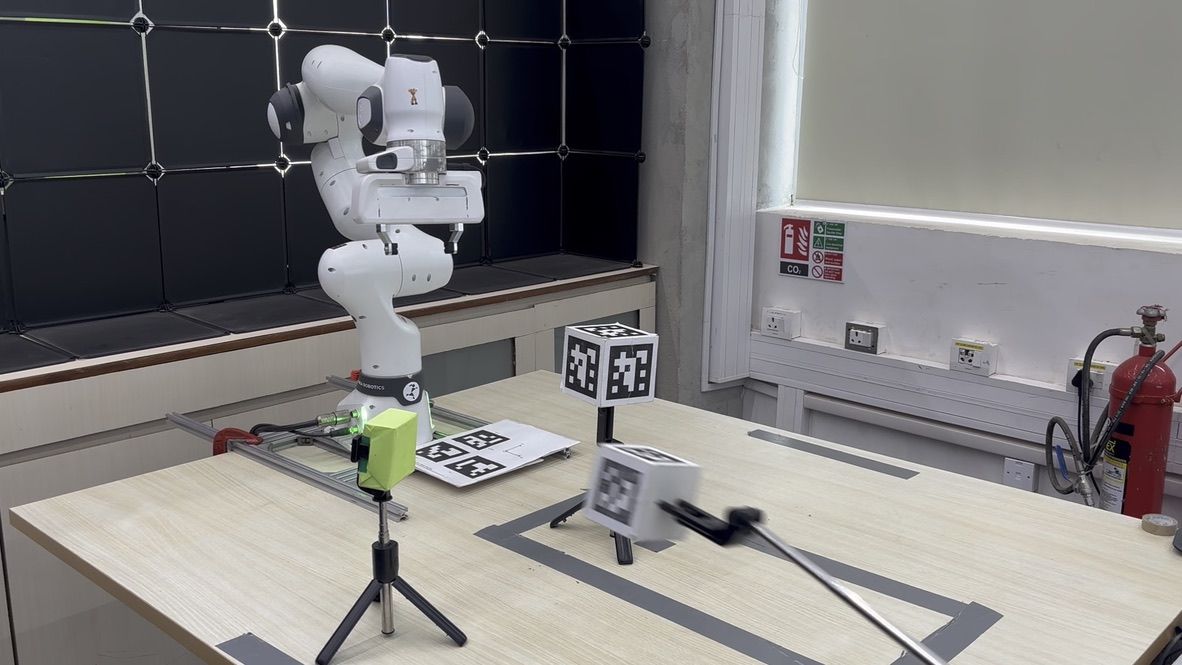
Experiments on a Franka Research 3: what happens when theory meets hardware. Videos coming soon.
04 / PLAY
Eleven short levels, from pointing an arm to giving it a sense of touch. Win a level to unlock the next. No maths needed to play; it’s there if you want it.
·
ABOUT
I work at the intersection of control theory, robotics, and physical human–robot interaction.
I completed my Ph.D. at IIT Delhi with Prof. Indra Narayan Kar (defended July 2026, awarded August 2026), on safe and compliant adaptive control for human–robot interaction: fixed-time parameter estimation, invariance-based safe admittance control, and observers that recover interaction forces without a force sensor.
Today I am a Research Associate at FOCAS Lab, Robert Bosch Centre for Cyber-Physical Systems, IISc Bangalore, led by Dr. Pushpak Jagtap. I work on model-free, funnel-based control and formal safety guarantees for robot manipulators, and I mentor a Ph.D. student and a research intern.
I like taking proofs all the way to hardware: Franka Research 3, Quanser rotary servo and 2-DOF helicopter platforms, with ROS 2, Python and MATLAB/Simulink.
Research Associate · FOCAS Lab, Robert Bosch Centre for Cyber-Physical Systems
Host: Dr. Pushpak Jagtap · funnel-based control, safety guarantees for manipulators, formal methods · mentoring a Ph.D. student and an intern
Ph.D., Electrical Engineering (Control & Automation) · CGPA 9.40/10
Thesis: Safe and Compliant Adaptive Control Strategies for Human–Robot Interaction · Advisor: Prof. Indra Narayan Kar · Prime Minister’s Research Fellow
B.Tech., Electrical Engineering · CGPA 8.32/10
Final-year project: Hilbert-transform fault detection with FPGA implementation · research internships at IIT (BHU) Varanasi and IIESTIndia’s most competitive doctoral fellowship, awarded nationally by the Ministry of Education across all of science and engineering. It funded my full doctorate, hardware and conference travel.
The highest outcome of the national PMRF review committee, given to a select fraction of fellows.
Robust fixed-time adaptive control with D. Efimov and R. Ushirobira.
For the MS(R) (2020) and Ph.D. (2021) at IIT Delhi. Selected as Graduate Engineer Trainee at Larsen & Toubro (2019), declined to pursue research.
Teaching at four institutions, mentoring, and taking science beyond the classroom.
2022 — 2025Laboratories and tutorials in basic electrical engineering, control engineering, nonlinear systems and robotics.
Taught discrete-time control theory and supervised the associated laboratory experiments.
Classes and laboratories in basic electrical and electronics engineering.
Hands-on AC–DC and rectifier circuits with Class X–XII students, under the PMRF outreach programme.
BEYOND THE LAB
Hiking, travelling, and seeing familiar things from a different angle.
LET’S CONNECT
I’m happy to talk about research
collaborations in robotics and control.